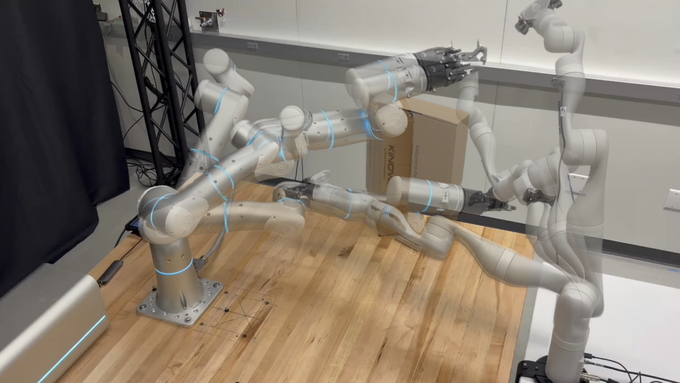
MR. POP: Multi-Robot Parallel Optimizing Planner for Almost-Surely Asymptotically Optimal Planning
Abstract
Finding globally optimal paths remains a fundamental challenge in multi-robot motion planning. Despite acceleration of almost-surely asymptotically optimal (a.s.a.o.) planners via CPU-based parallelism, achieving both probabilistic convergence guarantees and strong computational performance, these algorithms still struggle to scale to multi-robot settings. As such, we introduce MR. POP, a GPU-based a.s.a.o. multi-robot planner based on dRRT and the AO-x meta-algorithm. MR. POP uses large-scale GPU-based SIMT-parallelism to simultaneously run hundreds of roadmap construction and tree search iterations with underlying parallel nearest neighbor search and collision checking operations. We show that this enables MR. POP to become the only planner achieving a 100% solve rate while being faster than state-of-the-art a.s.a.o. planners in multi-robot systems up to 35-DOF. MR. POP also raises the success rate of downstream motion optimizers (e.g., from 4% to 72%), by creating high-quality, diverse seeds that help avoid local minima.
